Category
AI & Vision
Computer vision, SLAM, AI hardware, and machine perception.
3D LiDAR SLAM with FAST-LIO2: Real-Time Point Cloud Registration on NVIDIA Jetson Orin Nano
Plan a FAST-LIO2 mapping pipeline on Jetson Orin Nano. Check ROS port compatibility, Livox timestamps, IMU extrinsics, map growth, and performance budgets.
RealSense D435i vs Stereolabs ZED 2i: Visual-Inertial Odometry Comparison and Benchmark Method
Compare RealSense D435i and ZED 2i for visual-inertial odometry. Learn sensing limits, timing, calibration, and a reproducible method for measuring drift.
Deploying INT8-Quantized YOLOv10 with NVIDIA TensorRT for Low-Latency Robotic Obstacle Detection
Deploy YOLOv10 with TensorRT on Jetson. Match preprocessing, calibrate INT8, validate accuracy, and measure end-to-end robot detection latency.
How to Train a Custom Object Detection Model for Your Robot
A practical guide to collecting training data, labeling images, fine-tuning a detection model, and deploying it to a robot's edge hardware.
Best Jetson Boards for Edge AI Robotics in 2026
A guide to NVIDIA's current Jetson lineup — Orin Nano, Orin NX, and AGX Orin — and which board fits which kind of edge AI robotics project.
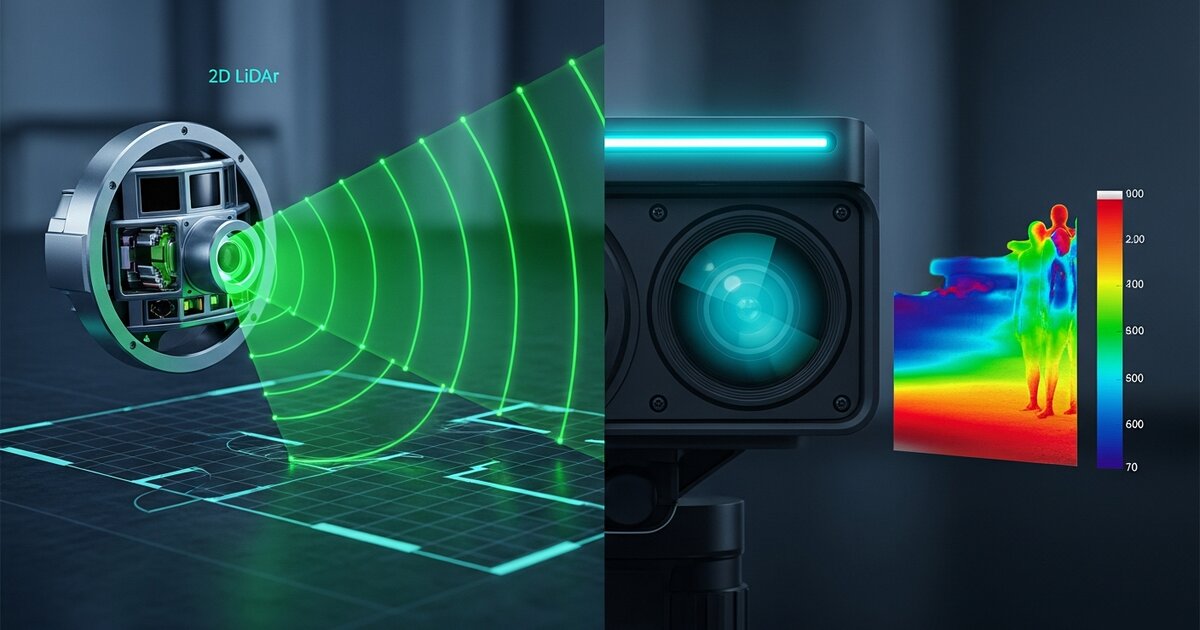
LiDAR vs Depth Cameras: Which Sensor Is Right for Your Robot?
A comparison of 2D LiDAR and depth cameras (like the OAK-D) for robot spatial awareness, covering accuracy, cost, SLAM support, and use-case fit.
Best AI Cameras for Robotics in 2026
Comparing the OAK-D, OpenMV, and Jetson-compatible cameras for embedded computer vision tasks.
SLAM Explained: How Robots Build Maps and Find Themselves
A technical breakdown of Simultaneous Localization and Mapping (SLAM) algorithms and hardware requirements.
AI for Robotics: The Complete 2026 Guide
An overview of how AI and machine learning are applied in modern robotics, from perception to path planning.