#Microcontrollers
Arduino, Raspberry Pi, ESP32, STM32 — programming and integration.
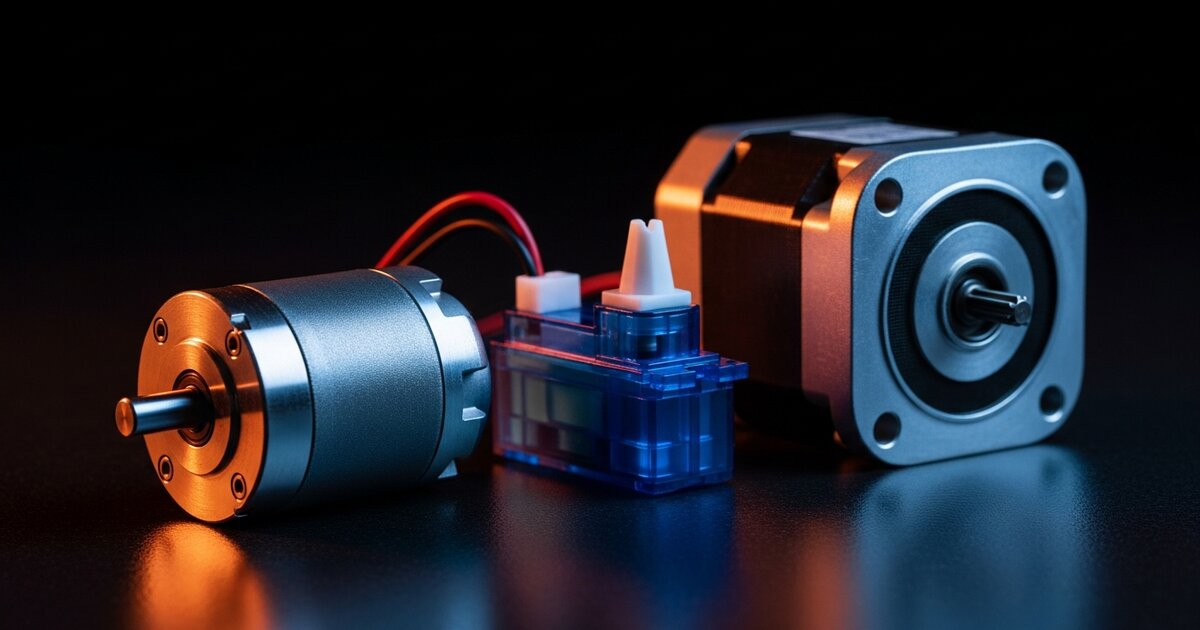
FOC vs Trapezoidal Commutation: Low-Speed Torque Control for Brushless Gimbal Actuators
Compare FOC and trapezoidal motor control for robotic joints. Learn torque ripple, AS5600 I2C feedback, STM32 setup, and safe SimpleFOC voltage-mode limits.
Micro-ROS on ESP32 and STM32: Publishing Real-Time Sensor Telemetry over XRCE-DDS
Connect ESP32 and STM32 firmware to ROS 2 with micro-ROS. Understand XRCE-DDS, serial transport, memory ownership, time sync, and telemetry validation.
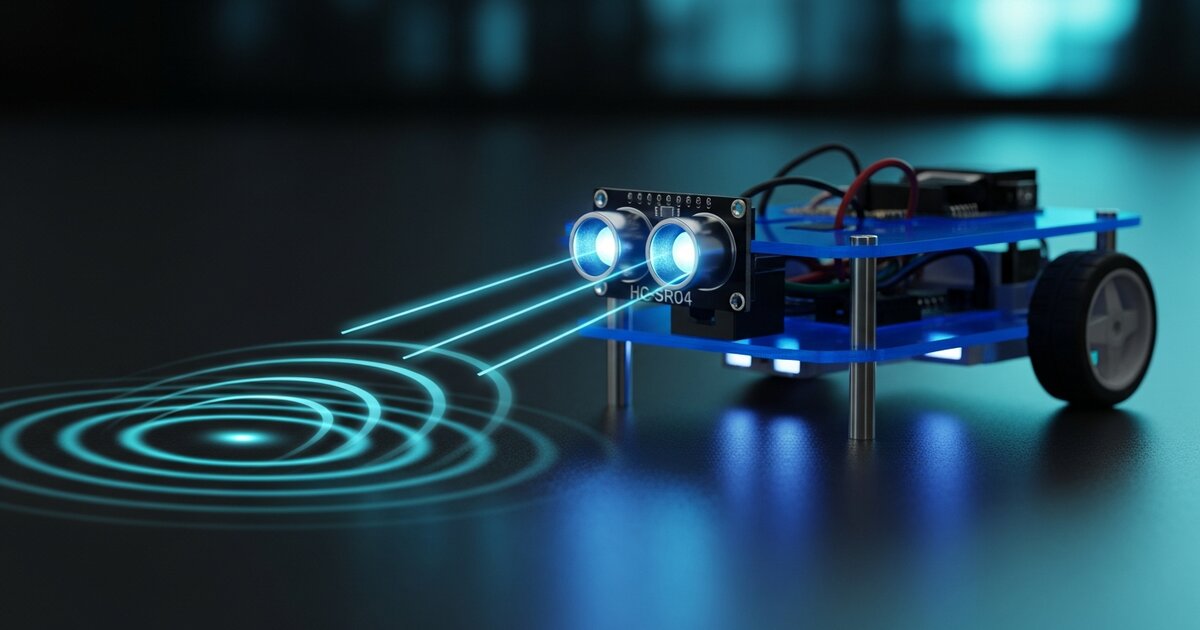
Build a Robot That Avoids Obstacles Using Ultrasonic Sensors (Beginner Version)
A beginner obstacle-avoidance robot using a single HC-SR04 ultrasonic sensor and an Arduino — the stepping stone between a line follower and a full LiDAR build.
ROS 2 for Beginners: Setting Up Your First Project
A gentle introduction to ROS 2 concepts, installation, and getting a first publisher/subscriber project running before diving into Nav2 and SLAM.
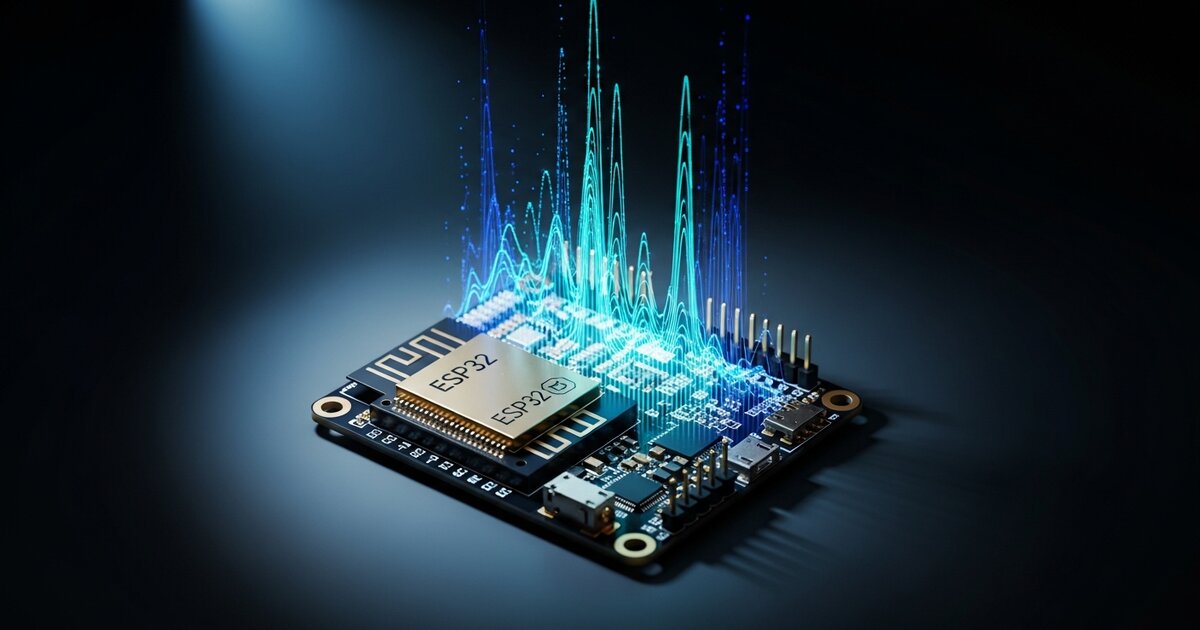
Build a Voice-Controlled Robot with ESP32 and AI
A step-by-step guide to building a wheeled robot that responds to spoken commands using an ESP32, an I2S microphone, and a cloud speech-to-text API.
Top 7 Robot Arm Kits for Hobbyists in 2026
A skill-level breakdown of the best robot arm kits in 2026, from beginner acrylic kits to ROS 2-ready 6-DOF arms.
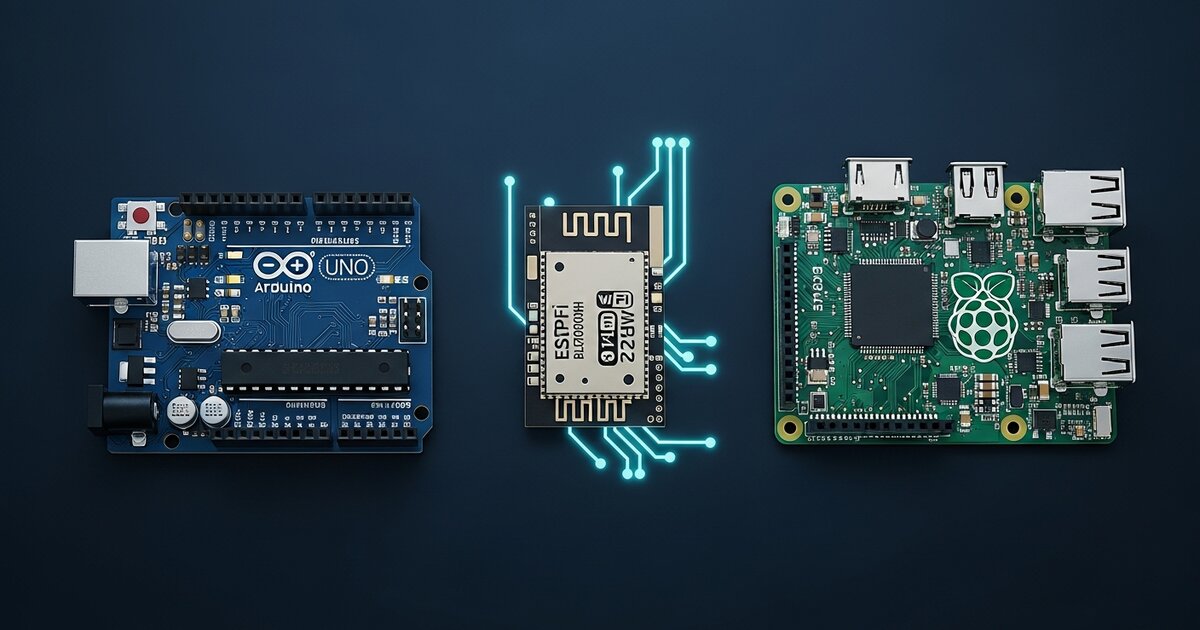
ESP32 vs Arduino vs Raspberry Pi for Robotics: Which Should You Buy?
A practical comparison of Arduino, ESP32, and Raspberry Pi — and how to pick the right brain for your robot build.
Build a Line-Following Robot from Scratch
A practical, step-by-step engineering guide to building a PID-controlled line following robot.
Best Robotics Starter Kits 2026
A roundup of the top 5 robotics starter kits for beginners, focusing on educational value and hardware quality.
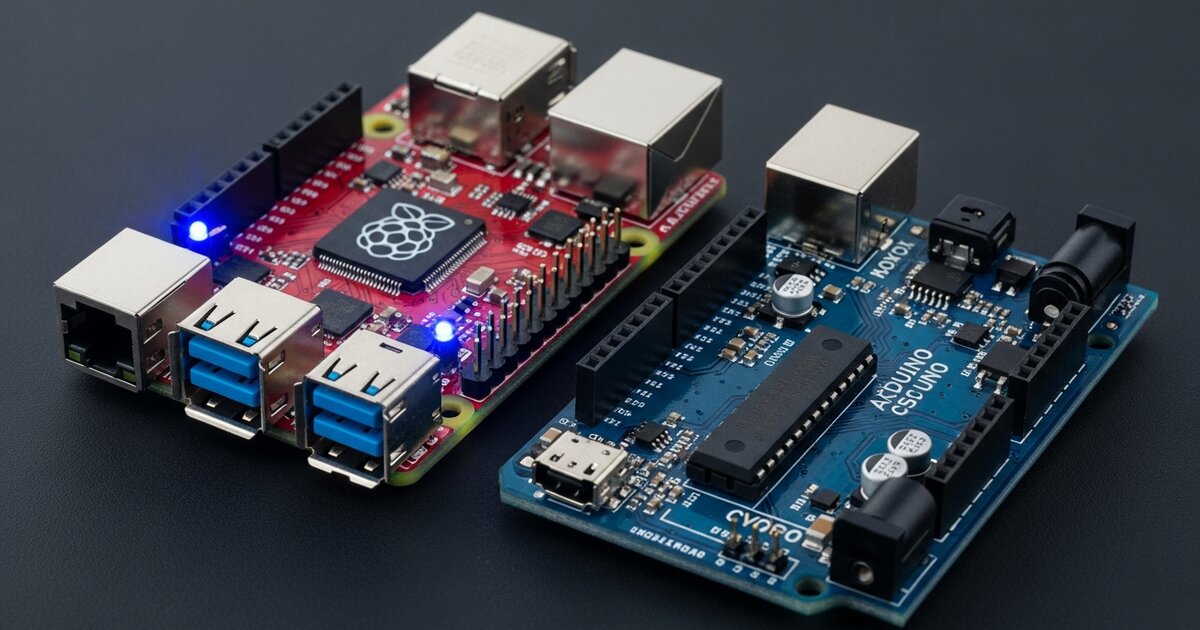
Best Microcontrollers for Robotics in 2026
Comparing Arduino Uno, Raspberry Pi, ESP32, and STM32 for different robotics applications.
Robotics 101: A Complete Beginner's Guide (2026)
A comprehensive introduction to robotics, covering sensing, actuation, computation, power, and getting started.